evroc Cloud Controller Manager
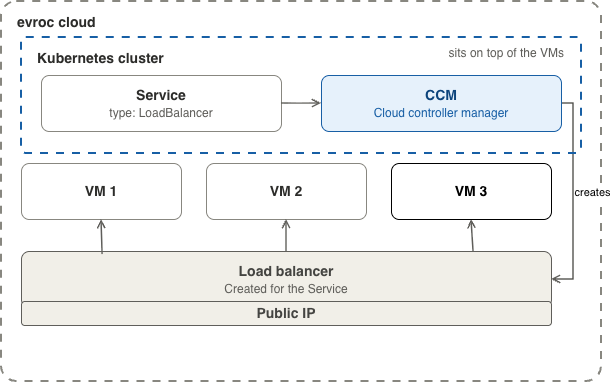
The evroc CCM integrates a self-managed Kubernetes cluster with the evroc cloud platform: it labels nodes with topology metadata, syncs addresses and provider IDs, and backs type: LoadBalancer services with evroc load balancers.
For installation, configuration, and reference, see the GitHub repository. For a walkthrough that includes the CCM, see Deploy a self-managed cluster.
Requirements
- Node names must equal evroc VM names - the CCM looks VMs up by node name.
- Kubelets must run with
--cloud-provider=external. On k3s/RKE2, setdisable-cloud-controller: trueandkubelet-arg: ["cloud-provider=external"].
Load balancers
The CCM provisions an evroc load balancer, public IP, and backend pool for each type: LoadBalancer service. The node-port range (30000-32767) must be open in your security group for the load balancer to reach nodes. Traffic to the public IP is forwarded from the load balancer to a node port on any node in the cluster, and then from there onto the relevant service.
For a detailed explanation of annotations, external traffic policy, and supported service fields, see the GitHub README.
Learn more
- evroc CCM driver - source code, examples, and the Helm chart
- Load balancer - the evroc L4 load balancer service
- Deploy a self-managed cluster - end-to-end guide including CCM